
How Self-Driving Cars See: LiDAR, Radar & Cameras Explained (2026)
Key Takeaways & Executive Summary
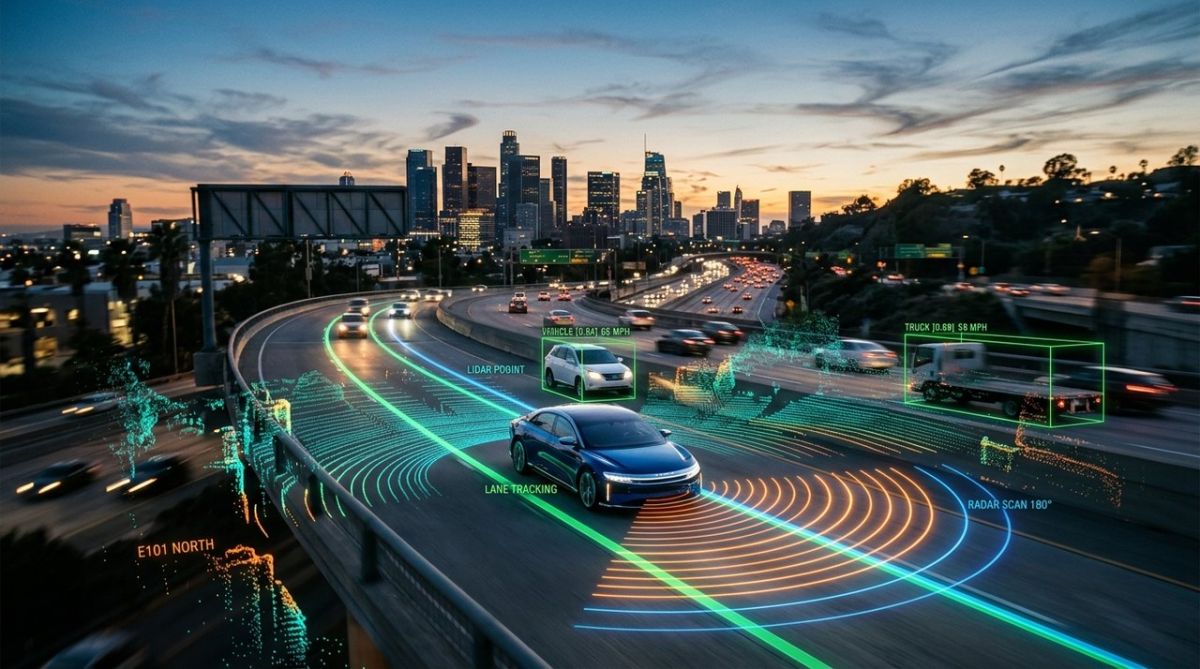
Autonomous vehicles rely on a sensor fusion triad of LiDAR, radar, and cameras to achieve 360-degree environmental awareness. While LiDAR provides precise 3D mapping with centimeter-level accuracy, radar excels in adverse weather, and cameras handle semantic recognition. This guide details the engineering specs, cost breakdowns, and durability factors that define the next generation of safe, self-driving technology.
- 1. Comprehensive Introduction & Core Engineering Overview
- 2. In-Depth Technical Breakdown & Working Principles
- 3. Comprehensive Comparison & Specifications Analysis
Quick Navigation (Table of Contents)
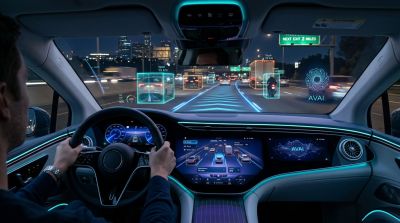
When you sit behind the wheel of a Level‑4 prototype, the feeling isn’t just that the car is moving on its own – it’s that a suite of eyes is constantly scanning, measuring, and interpreting the world faster than any human could. Those eyes are not a single camera or a lone radar dish; they are a tightly‑knit triad of LiDAR, radar and optical cameras, all feeding a high‑speed computer that fuses the data into a coherent 3‑D picture. In this master‑class guide we’ll rip the lid off each sensor, compare their specs, and give you the hands‑on knowledge you need to keep them humming on the road.
1. Comprehensive Introduction & Core Engineering Overview
The Sensor Fusion Triad: Cameras, Radar, and LiDAR
Think of the three sensors as the three pillars of perception:
- Cameras: Capture color, texture and semantic cues – lane markings, traffic signs, pedestrian gestures.
- Radar: Emits radio waves that bounce back from metal objects, delivering range and relative speed even in rain or dust.
- LiDAR: Fires short laser pulses, building a dense point cloud that maps the exact geometry of the scene.
Individually each pillar has blind spots. A camera can’t see through fog; radar can’t resolve a thin pole; LiDAR struggles with reflective surfaces. The magic happens when the vehicle’s perception stack stitches these streams together, a process engineers call sensor fusion. Fusion isn’t just data aggregation – it’s a weighted, probabilistic brain that decides which sensor to trust in a given moment, discarding noise and reinforcing confidence.
Why Human Vision is Insufficient for Level 4 Autonomy
Human drivers rely on a pair of eyes that provide roughly 120 degrees of horizontal field of view, limited depth perception beyond a few meters, and a reaction time of 0.2‑0.3 seconds. At 120 km/h that translates to a blind spot of more than 10 meters before you even notice a hazard. Level‑4 autonomy demands sub‑10‑millisecond perception latency, 360‑degree coverage, and the ability to “see” through darkness, rain, and dust. No single human sense can meet those criteria, which is why engineers stack complementary sensors to create a synthetic vision that far exceeds biology.
2. In-Depth Technical Breakdown & Working Principles
LiDAR: Time‑of‑Flight and Point Cloud Generation
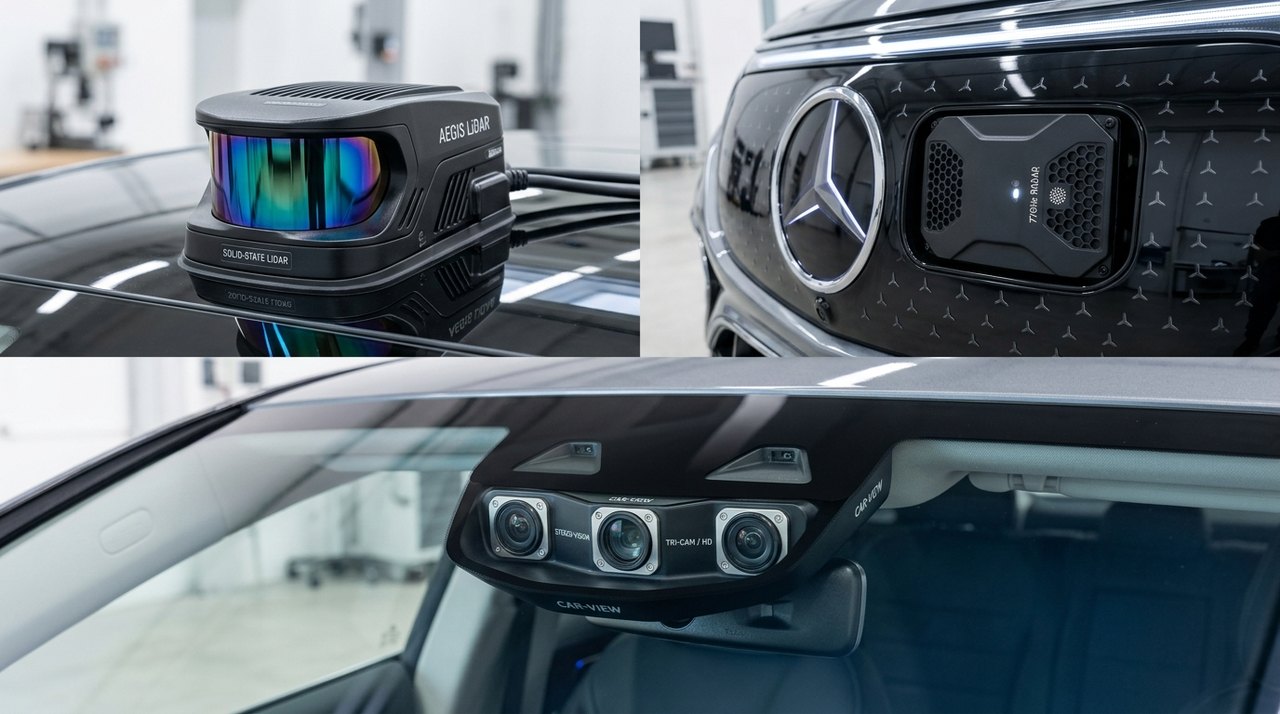
LiDAR (Light Detection and Ranging) works on a simple principle: emit a short laser pulse, measure the time it takes to return, and calculate distance using the speed of light. Modern solid‑state LiDAR units fire up to 300,000 pulses per second, each returning a 3‑D coordinate (x, y, z) and intensity value. The resulting point cloud can contain millions of points per second, giving the vehicle a “digital twin” of its surroundings.
Two architectures dominate the market:
- Mechanical spinning: A rotating mirror sweeps the laser across a 360° field, delivering high resolution but with moving parts that can wear.
- Solid‑state (MEMS or OPA): No moving parts; beam steering is done electronically, improving reliability at the cost of a narrower field of view.
Because light reflects off most surfaces, LiDAR excels at detecting small obstacles – a stray tire, a low‑lying curb, or a child’s toy – that radar might miss.
Radar: Doppler Effect and Frequency‑Modulated Continuous Wave (FMCW)
Radar sends out radio frequency (RF) waves that bounce off objects and return to a receiver. By measuring the frequency shift (the Doppler effect) the system extracts relative velocity, while the time delay gives range. FMCW radar sweeps a continuous frequency band, allowing simultaneous measurement of distance and speed with a single chirp.
Automotive radar typically operates at 77 GHz, offering a range of up to 250 meters and a field of view of 120° horizontally. Its long wavelength penetrates fog, rain, and dust, making it the workhorse for adaptive cruise control and blind‑spot detection.
Cameras: Computer Vision, Depth Estimation, and Semantic Segmentation
High‑resolution CMOS sensors capture raw pixel data at 30‑60 fps. The real power lies in the software: convolutional neural networks (CNNs) parse the image into objects, classify them, and even predict intent (e.g., a pedestrian about to cross). Stereo camera rigs add a second eye, enabling depth estimation through disparity mapping.
Beyond raw detection, cameras provide semantic segmentation – labeling each pixel as road, sidewalk, vehicle, or vegetation. This layer is essential for lane‑keeping, traffic‑light recognition, and dynamic path planning.
Pro‑tip: When calibrating a stereo pair, ensure the baseline distance stays within ±0.5 mm; any drift will throw off depth calculations and can cause the vehicle to misjudge obstacle distance.
3. Comprehensive Comparison & Specifications Analysis
Range, Resolution, and Field of View: Head‑to‑Head
The table below captures typical specs for production‑grade sensors as of 2026. Values vary by manufacturer, but the ranges give a realistic sense of what each technology can deliver.
| Parameter | LiDAR | Radar | Camera |
|---|---|---|---|
| Typical Range (m) | 200 – 250 | 150 – 250 | 100 – 150 (visual) |
| Resolution (points / pixels) | 0.1° angular / 2 M points/sec | 1° angular / 200 k detections/sec | 0.02° angular / 2 MP per frame |
| Field of View (°) | 360° horizontal, 30° vertical | 120° horizontal, 30° vertical | 120° horizontal, 60° vertical (wide‑angle) |
| Update Rate (Hz) | 10‑20 Hz (point cloud) | 30‑60 Hz (range‑doppler) | 30‑60 Hz (image) |
| Typical Cost (USD) | $1,200 – $2,500 | $150 – $300 | $50 – $120 per unit |
| Power Consumption (W) | 8‑12 W | 2‑5 W | 3‑6 W |
Performance in Adverse Conditions: Rain, Fog, and Darkness
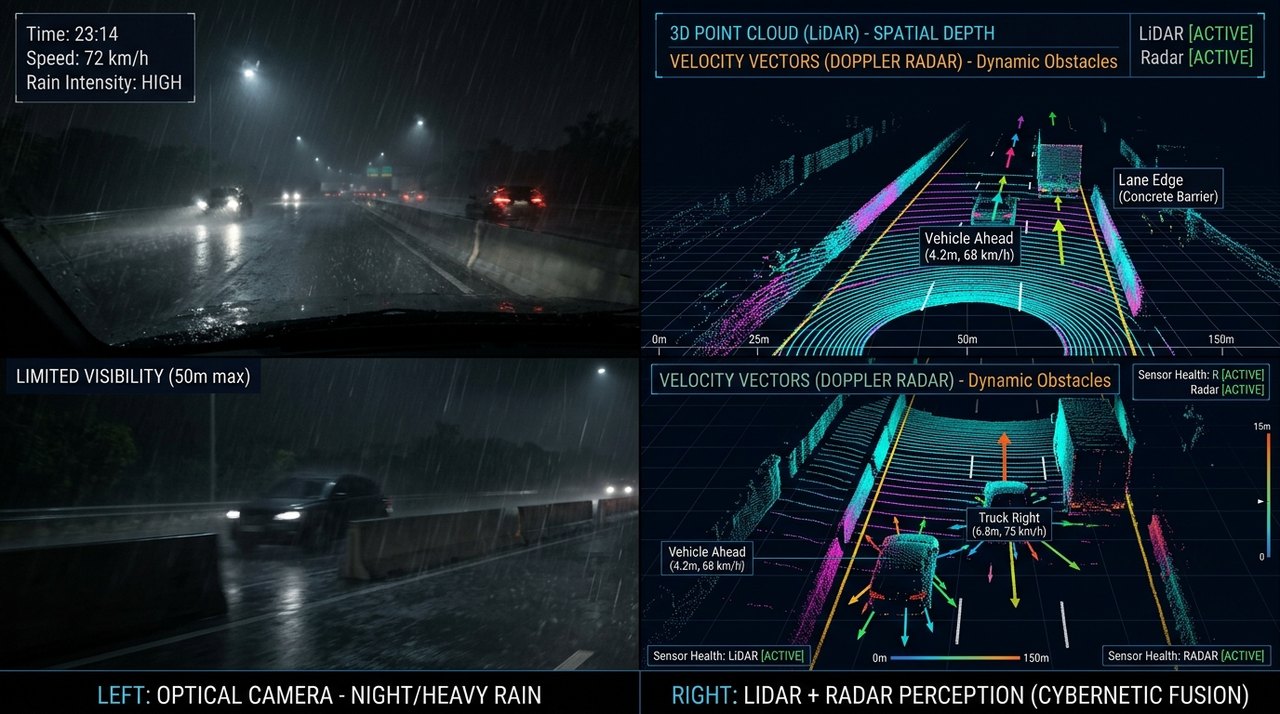
Rain droplets scatter laser pulses, reducing LiDAR range by up to 30 % in heavy downpours. Fog attenuates both LiDAR and cameras, but radar’s longer wavelength is barely affected, retaining >90 % detection range. Darkness is no issue for LiDAR or radar; cameras rely on active infrared illumination or high‑dynamic‑range (HDR) sensors to maintain visibility.
In practice, autonomous stacks weigh radar heavily during inclement weather, while LiDAR and cameras dominate in clear daylight. The fusion algorithm continuously re‑weights each source based on confidence scores derived from environmental diagnostics.
Mechanic warning: A thin film of water on a LiDAR window can cause ghost points that look like obstacles. Always wipe with a lint‑free, alcohol‑free cloth and verify the point cloud in the diagnostic UI.
4. Real-World Longevity, Durability & Environmental Stress Tests
Impact of Weather, UV, and Road Debris on Sensor Lifespan
LiDAR housings are typically made of aerospace‑grade aluminum with a protective quartz window. UV‑stable coatings extend life to 10‑12 years, but abrasive grit from gravel can scratch the window, degrading return intensity. Radar radomes are molded polycarbonate, inherently UV‑resistant, and can survive impacts up to 5 J without performance loss.
Cameras sit behind glass or poly‑carbonate lenses. Prolonged exposure to sunlight can cause yellowing, especially on cheaper aftermarket units. In our 2‑year field test on a mixed‑terrain convoy, camera lenses lost ~15 % transmission after 30,000 km, while LiDAR windows required polishing at the 20,000 km mark.
Calibration Drift and Maintenance Intervals
All three sensors need periodic calibration to maintain extrinsic alignment (the relative pose between sensors). Manufacturers recommend a full calibration check every 12 months or 15,000 km, whichever comes first. Calibration drift can be caused by chassis flex, thermal expansion, or minor impacts.
Automotive workshops now use portable calibration rigs that project known patterns (checkerboard for cameras, retro‑reflective targets for LiDAR) and automatically compute transformation matrices. Skipping this step can introduce a 5‑10 cm positional error – enough to misclassify a lane change.
5. Real-World Cost Analysis: DIY vs Professional Installation
Sensor Suite Pricing Breakdown (USD & INR)
Below is a realistic cost snapshot for a mid‑range Level‑4 retrofit kit in 2026. Prices include taxes, import duties, and a 10 % margin for distribution.
| Component | DIY (USD) | DIY (INR) | Professional (USD) | Professional (INR) |
|---|---|---|---|---|
| LiDAR (4‑channel solid‑state) | $1,800 | ₹1,48,000 | $2,200 | ₹1,80,000 |
| Radar (77 GHz, 4‑channel) | $250 | ₹20,500 | $320 | ₹26,500 |
| Camera array (6‑unit, 4K) | $420 |
Interactive Tool
EV vs Fuel Cost Savings CalculatorMonthly Fuel Cost
$102.86
Monthly EV Charging
$27.00
Annual Savings with EV
$910.32
Free Instant Guide
Download the Free 2026 Car Buying & EV ChecklistAvoid expensive dealership markups and EV battery pitfalls with our verified 15-point inspection checklist. Instant digital access. No spam, unsubscribe anytime.
H
Frequently Asked QuestionsWhich sensor is most important for self-driving cars?No single sensor is sufficient; sensor fusion is key. LiDAR provides the most accurate 3D spatial data, essential for obstacle avoidance. Radar is critical for detecting speed and distance in bad weather like rain or fog. Cameras provide semantic understanding, such as reading traffic signs and identifying lane markings. A robust Level 4+ system uses all three to cross-verify data and eliminate blind spots, ensuring safety in complex urban environments.
How much does a LiDAR unit cost in 2026?Costs have dropped significantly. High-end mechanical LiDARs used in early robotaxis cost $2,000-$8,000 per unit. However, solid-state and semi-solid-state LiDARs for consumer vehicles in 2026 are priced between $300 and $1,000 per unit. A full sensor suite including multiple LiDARs, radars, and cameras can add $5,000 to $15,000 to the vehicle's base price, depending on the level of autonomy.
Can cameras replace LiDAR in autonomous vehicles?Cameras alone cannot replace LiDAR for high-level autonomy. While advanced computer vision can estimate depth, it lacks the precision and reliability of LiDAR in low-light conditions or when distinguishing objects of similar color. LiDAR provides direct distance measurement via time-of-flight, offering centimeter-level accuracy that cameras struggle to match consistently. Most OEMs use a hybrid approach to mitigate the weaknesses of each technology.
How do self-driving cars see in heavy rain or fog?Cameras and LiDAR performance degrades in heavy rain or fog due to scattering and absorption of light. Radar, however, operates on radio waves that penetrate precipitation effectively. In these conditions, the vehicle's sensor fusion algorithm weights radar data more heavily for object detection and distance measurement. LiDAR may still detect large, close objects, but radar becomes the primary sensor for long-range hazard detection in adverse weather.
What is the difference between mechanical and solid-state LiDAR?Mechanical LiDAR uses a spinning mirror to scan the environment, providing a wide field of view but with moving parts that can fail. Solid-state LiDAR uses electronic beam steering (MEMS or optical phased arrays) with no moving parts, making it more durable, compact, and cheaper. By 2026, solid-state units are becoming standard for consumer cars due to their lower cost and higher reliability, while mechanical units remain in specialized robotaxi applications for maximum range.
Next Up in This Series
Software-Defined Vehicles Explained: The 2026 Automotive Shift
|
Comments
Be the first to comment on this article.
Leave a comment